This magic trick is an optical illusion instead of a pure magic trick, but it definitely is a crowd-pleaser. This illusion is called Sugihara’s Impossible Cylinder:
This is actually a mathematical magic trick. As detailed by David Richeson in Math Horizons, there is a fair amount of math that goes into creating this unique shape. He also provided this interacted Geogebra applet as well as a printable pdf file for creating this illusion.
At long last, we have reached the end of this series of posts.
The derivation is elementary; I’m confident that I could have understood this derivation had I seen it when I was in high school. That said, the word “elementary” in mathematics can be a bit loaded — this means that it is based on simple ideas that are perhaps used in a profound and surprising way. Perhaps my favorite quote along these lines was this understated gem from the book Three Pearls of Number Theory after the conclusion of a very complicated proof in Chapter 1:
You see how complicated an entirely elementary construction can sometimes be. And yet this is not an extreme case; in the next chapter you will encounter just as elementary a construction which is considerably more complicated.
Here are the elementary ideas from calculus, precalculus, and high school physics that were used in this series:
Physics
Conservation of angular momentum
Newton’s Second Law
Newton’s Law of Gravitation
Precalculus
Completing the square
Quadratic formula
Factoring polynomials
Complex roots of polynomials
Bounds on and
Period of and
Zeroes of and
Trigonometric identities (Pythagorean, sum and difference, double-angle)
Conic sections
Graphing in polar coordinates
Two-dimensional vectors
Dot products of two-dimensional vectors (especially perpendicular vectors)
Euler’s equation
Calculus
The Chain Rule
Derivatives of and
Linearizations of , , and near (or, more generally, their Taylor series approximations)
Derivative of
Solving initial-value problems
Integration by substitution
While these ideas from calculus are elementary, they were certainly used in clever and unusual ways throughout the derivation.
I should add that although the derivation was elementary, certain parts of the derivation could be made easier by appealing to standard concepts from differential equations.
One more thought. While this series of post was inspired by a calculation that appeared in an undergraduate physics textbook, I had thought that this series might be worthy of publication in a mathematical journal as an historical example of an important problem that can be solved by elementary tools. Unfortunately for me, Hieu D. Nguyen’s terrific article Rearing Its Ugly Head: The Cosmological Constant and Newton’s Greatest Blunder in The American Mathematical Monthly is already in the record.
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
In this series, we found an approximate solution to the governing initial-value problem
,
where , , , is the gravitational constant of the universe, is the mass of the planet, is the mass of the Sun, is the constant angular momentum of the planet, is the eccentricity of the orbit, and is the speed of light.
We used the following steps to find an approximate solution.
Step 0. Ignore the general-relativity contribution and solve the simpler initial-value problem
,
which is a zeroth-order approximation to the real initial-value problem. We found that the solution of this differential equation is
,
which is the equation of an ellipse in polar coordinates.
Step 1. Solve the initial-value problem
,
which partially incorporates the term due to general relativity. This is a first-order approximation to the real differential equation. After much effort, we found that the solution of this initial-value problem is
.
For large values of , this is accurately approximated as:
,
which can be further approximated as
.
From this expression, the precession in a planet’s orbit due to general relativity can be calculated.
Roughly 20 years ago, I presented this application of differential equations at the annual meeting of the Texas Section of the Mathematical Association of America. After the talk, a member of the audience asked what would happen if we did this procedure yet again to find a second-order approximation. In other words, I was asked to consider…
Step 2. Solve the initial-value problem
.
It stands to reason that the answer should be an even more accurate approximation to the true solution .
I didn’t have an immediate answer for this question, but I can answer it now. Letting Mathematica do the work, here’s the answer:
Yes, it’s a mess. The term in red is , while the term in yellow is the next largest term in . Both of these appear in the answer to .
The term in green is the next largest term in , with the highest power of in the numerator and the highest power of in the denominator. In other words,
.
How does this compare to our previous approximation of
?
Well, to a second-order Taylor approximation, it’s the same! Let
.
Expanding about and treated as a constant, we find
.
Substituting yields the above approximation for .
Said another way, proceeding to a second-order approximation merely provides additional confirmation for the precession of a planet’s orbit.
Just for the fun of it, I also used Mathematica to find the solution of Step 3:
Step 2. Solve the initial-value problem
.
I won’t copy-and-paste the solution from Mathematica; unsurpisingly, it’s really long. I will say that, unsurprisingly, the leading terms are
.
I said “unsurprisingly” because this matches the third-order Taylor polynomial of our precession expression. I don’t have time to attempt it, but surely there’s a theorem to be proven here based on this computational evidence.
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
We have shown that under general relativity, the motion of a planet around the Sun precesses by
,
where is the semi-major axis of the planet’s orbit, is the orbit’s eccentricity, is the gravitational constant of the universe, is the mass of the Sun, and is the speed of light.
Notice that for to be as observable as possible, we’d like to be as small as possible and to be as large as possible. By a fortunate coincidence, the orbit of Mercury — the closest planet to the sun — has the most elliptical orbit of the eight planets.
Here are the values of the constants for Mercury’s orbit in the SI system:
The last constant, , is the time for Mercury to complete one orbit. This isn’t in the SI system, but using Earth years as the unit of time will prove useful later in this calculation.
Using these numbers, and recalling that , we find that
.
Notice that all of the units cancel out perfectly; this bit of dimensional analysis is a useful check against careless mistakes.
Again, the units of are in radians per Mercury orbit, or radians per 0.2408 years. We now convert this to arc seconds per century:
.
This indeed matches the observed precession in Mercury’s orbit, thus confirming Einstein’s theory of relativity.
This same computation can be made for other planets. For Venus, we have the new values of , , and . Repeating this calculation, we predict the precession in Venus’s orbit to be 8.65” per century. Einstein made this prediction in 1915, when the telescopes of the time were not good enough to measure the precession in Venus’s orbit. This only happened in 1960, 45 years later and 5 years after Einstein died. Not surprisingly, the precession in Venus’s orbit also agrees with general relativity.
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
We have shown that the motion of a planet around the Sun, expressed in polar coordinates with the Sun at the origin, under general relativity is
,
where , , is the semi-major axis of the planet’s orbit, is the orbit’s eccentricity, , is the gravitational constant of the universe, is the mass of the planet, is the mass of the Sun, is the planet’s perihelion, is the constant angular momentum of the planet, and is the speed of light.
The above function is maximized (i.e., the distance from the Sun is minimized) when is as large as possible. This occurs when is a multiple of .
Said another way, the planet is at its closest point to the Sun when . One orbit later, the planet returns to its closest point to the Sun when
We now use the approximation
;
this can be demonstrated by linearization, Taylor series, or using the first two terms of the geometric series . With this approximation, the closest approach to the Sun in the next orbit occurs when
,
which is coterminal with the angle
.
Substituting and , we see that the amount of precession per orbit is
.
The units of are radians per orbit. In the next post, we will use Mercury’s data to find in seconds of arc per century.
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
We have shown that the motion of a planet around the Sun, expressed in polar coordinates with the Sun at the origin, under general relativity is
,
where , , , , is the gravitational constant of the universe, is the mass of the planet, is the mass of the Sun, is the planet’s perihelion, is the constant angular momentum of the planet, and is the speed of light.
We notice that the orbit of a planet under general relativity looks very, very similar to the orbit under Newtonian physics:
,
so that
.
As we’ve seen, this describes an elliptical orbit, normally expressed in rectangular coordinates as
,
with semimajor axis along the axis. In particular, for an elliptical orbit, the planet’s closest approach to the Sun occurs at :
,
and the planet’s further distance from the Sun occurs at :
.
Therefore, the length of the major axis of the ellipse is the sum of these two distances:
.
Said another way, . This is a far more convenient formula for computing than , as the values of (the semi-major axis) and (the eccentricity of the orbit) are more accessible than the angular momentum of the planet’s orbit.
In the next post, we finally compute the precession of the orbit.
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
We have shown that the motion of a planet around the Sun, expressed in polar coordinates with the Sun at the origin, under general relativity is
,
where , , , is the gravitational constant of the universe, is the mass of the planet, is the mass of the Sun, is the constant angular momentum of the planet, and is the speed of light.
We will now simplify this expression, using the facts that is very small and is quite large, so that is very small indeed. We will use the two approximations
;
these approximations can be obtained by linearization or else using the first term of the Taylor series expansions of and about .
In this series, I’m discussing how ideas from calculus and precalculus (with a touch of differential equations) can predict the precession in Mercury’s orbit and thus confirm Einstein’s theory of general relativity. The origins of this series came from a class project that I assigned to my Differential Equations students maybe 20 years ago.
We have shown that the motion of a planet around the Sun, expressed in polar coordinates with the Sun at the origin, under general relativity is
,
where , , , is the gravitational constant of the universe, is the mass of the planet, is the mass of the Sun, is the constant angular momentum of the planet, and is the speed of light.
We notice that the first term of the above solution,
,
is the same as the solution found earlier under Newtonian physics, without general relativity. Therefore, the remaining terms describe the perturbation due to general relativity. All of these terms contain the small factor , and so these can be expected to be small adjustments to an elliptical orbit.
Of these terms, the terms
are constants, while the terms
is bounded since and . By contrast, the term
grows without bound. Therefore, for large values of , the planet’s orbit may be accurately described by only including this last perturbation:

 and

 ,
 , and
 near
 (or, more generally, their Taylor series approximations)

 substitution


 ,
 ,
 ,
 ,
 is the gravitational constant of the universe,
 is the mass of the planet,
 is the mass of the Sun,
 is the constant angular momentum of the planet,
 is the eccentricity of the orbit, and
 is the speed of light.


 ,
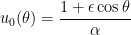 ,


 ,
 .
 , this is accurately approximated as:
 ,
 .


 .
 .

 , while the term in yellow is the next largest term in
 . Both of these appear in the answer to
 .

 in the denominator. In other words,
 .
 ?
 .
 and treated
 .
 yields the above approximation for


 .
 .
 .

 ,
 is the semi-major axis of the planet’s orbit,
 to be as observable as possible, we’d like


 , is the time for Mercury to complete one orbit. This isn’t in the SI system, but using Earth years as the unit of time will prove useful later in this calculation.
 , we find that
 .

 .
 ,
 , and
 . Repeating this calculation, we predict the precession in Venus’s orbit to be 8.65” per century. Einstein made this prediction in 1915, when the telescopes of the time were not good enough to measure the precession in Venus’s orbit. This only happened in 1960, 45 years later and 5 years after Einstein died. Not surprisingly, the precession in Venus’s orbit also agrees with general relativity.
 with the Sun at the origin, under general relativity is
 ,
 ,
 is the planet’s perihelion,
 is minimized) when
 is as large as possible. This occurs when
 is a multiple of
 .
 . One orbit later, the planet returns to its closest point to the Sun when


 ;
 . With this approximation, the closest approach to the Sun in the next orbit occurs when
 ,
 .
 .
 ,
 ,
 .
 ,
 axis. In particular, for an elliptical orbit, the planet’s closest approach to the Sun occurs at
 ,
 :
 .
 of the major axis of the ellipse is the sum of these two distances:


 .
 , as the values of
 with the Sun at the origin, under general relativity is
 ,
 is very small and
 is very small indeed. We will use the two approximations
 ;
 .


 .
 ,
 ,


 and
 . By contrast, the term

 .
 Mean Green Math
